Research Area
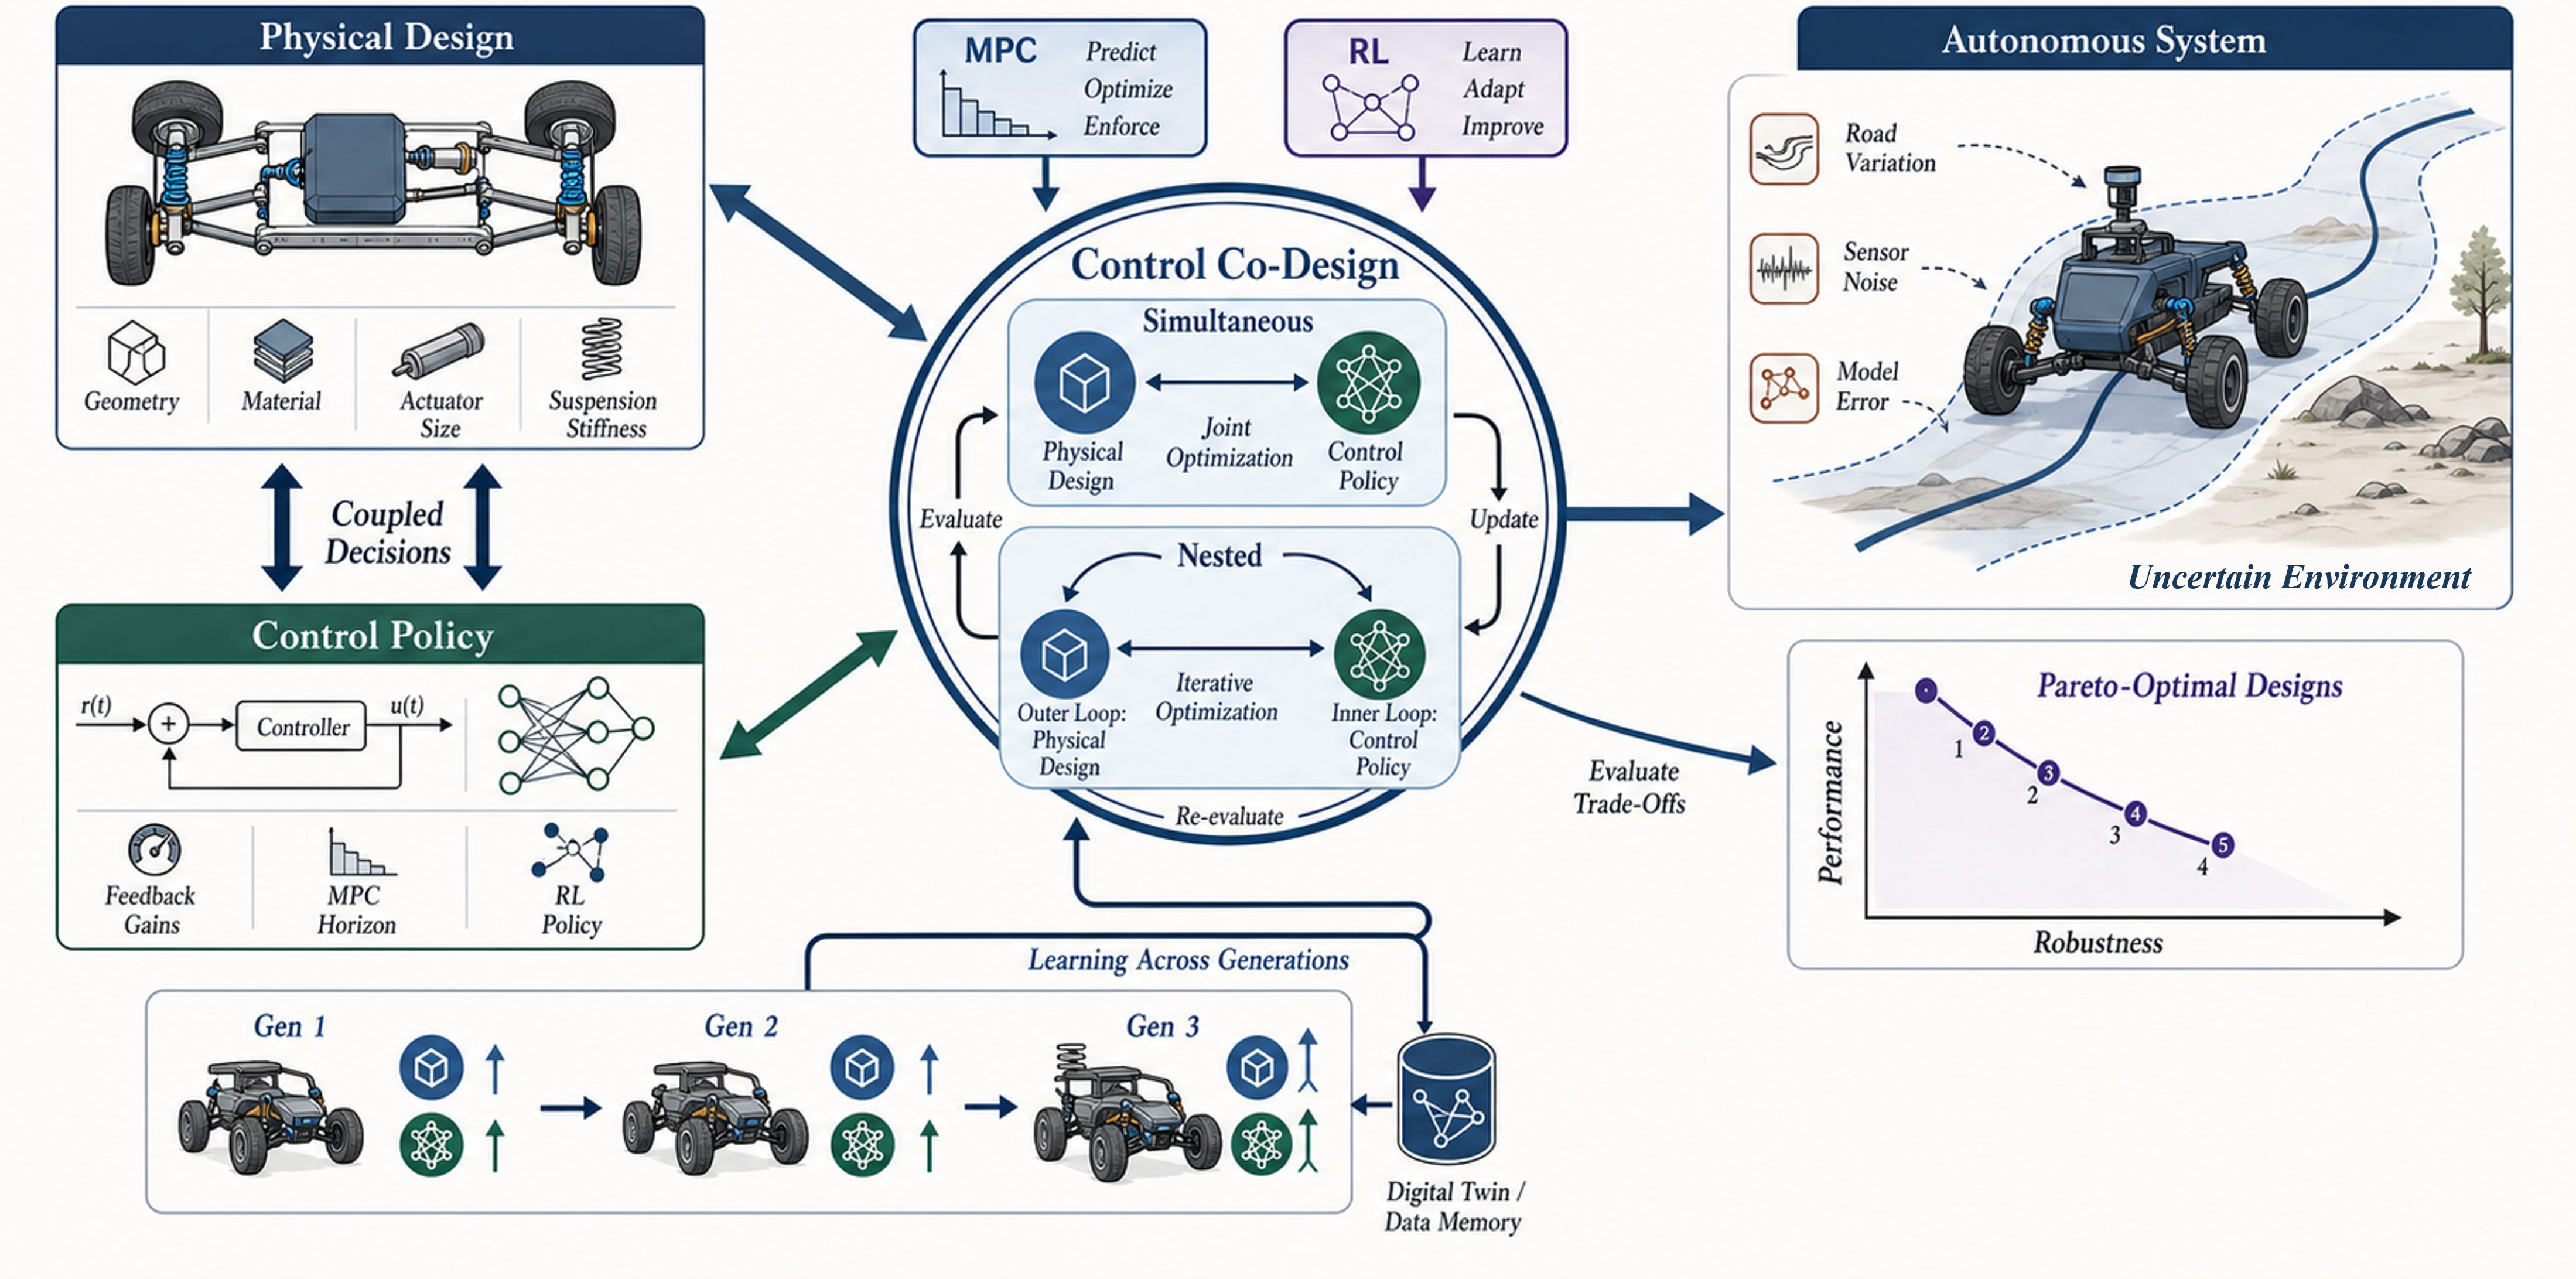
We advance control co-design (CCD) methodologies that integrate reinforcement learning (RL) and model predictive control (MPC) to jointly optimize physical design and control policies for autonomous systems operating in dynamic and uncertain environments.
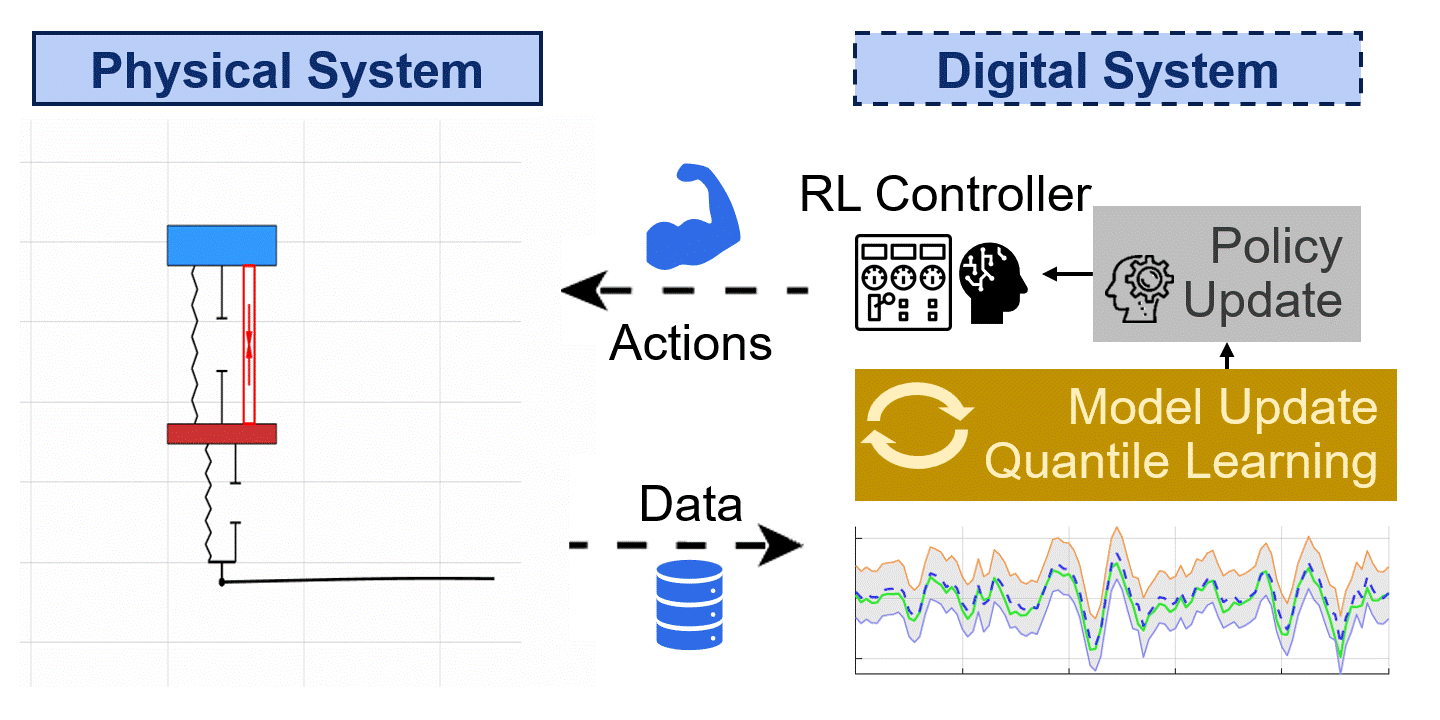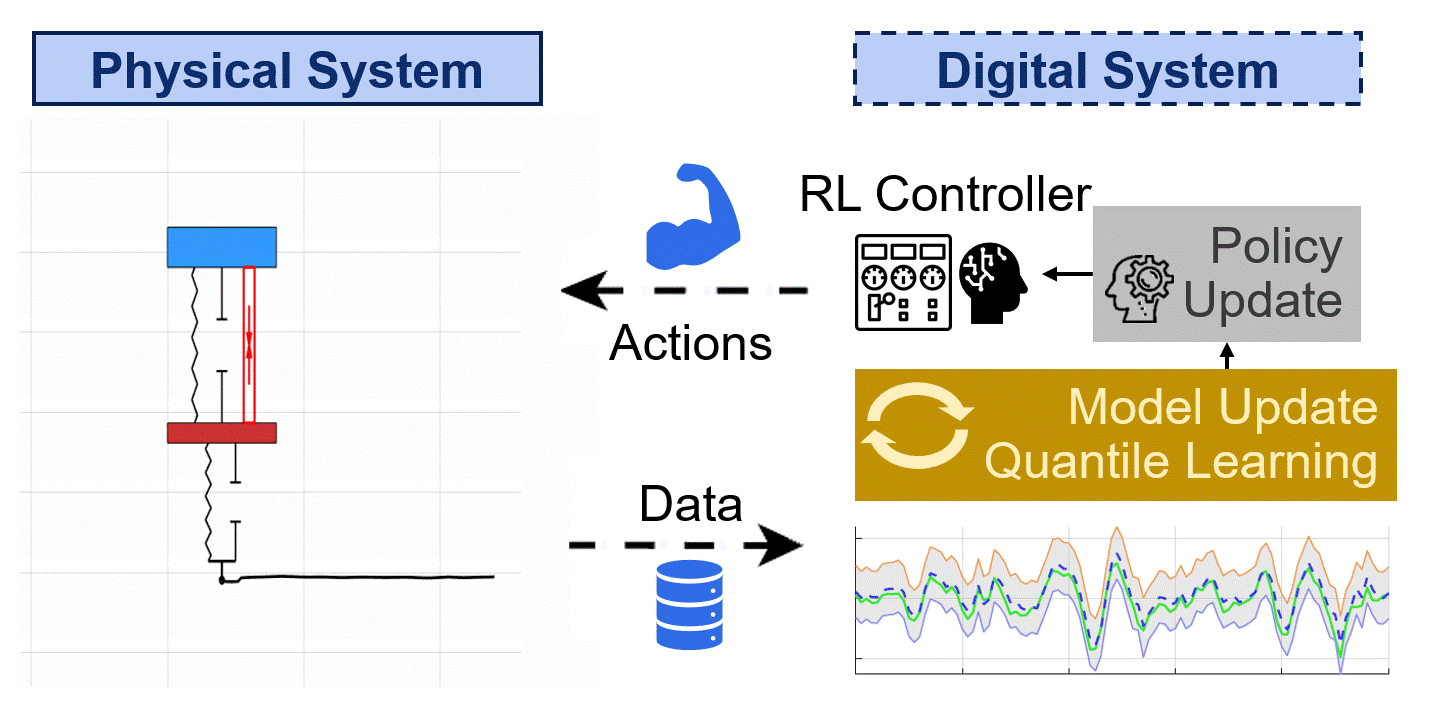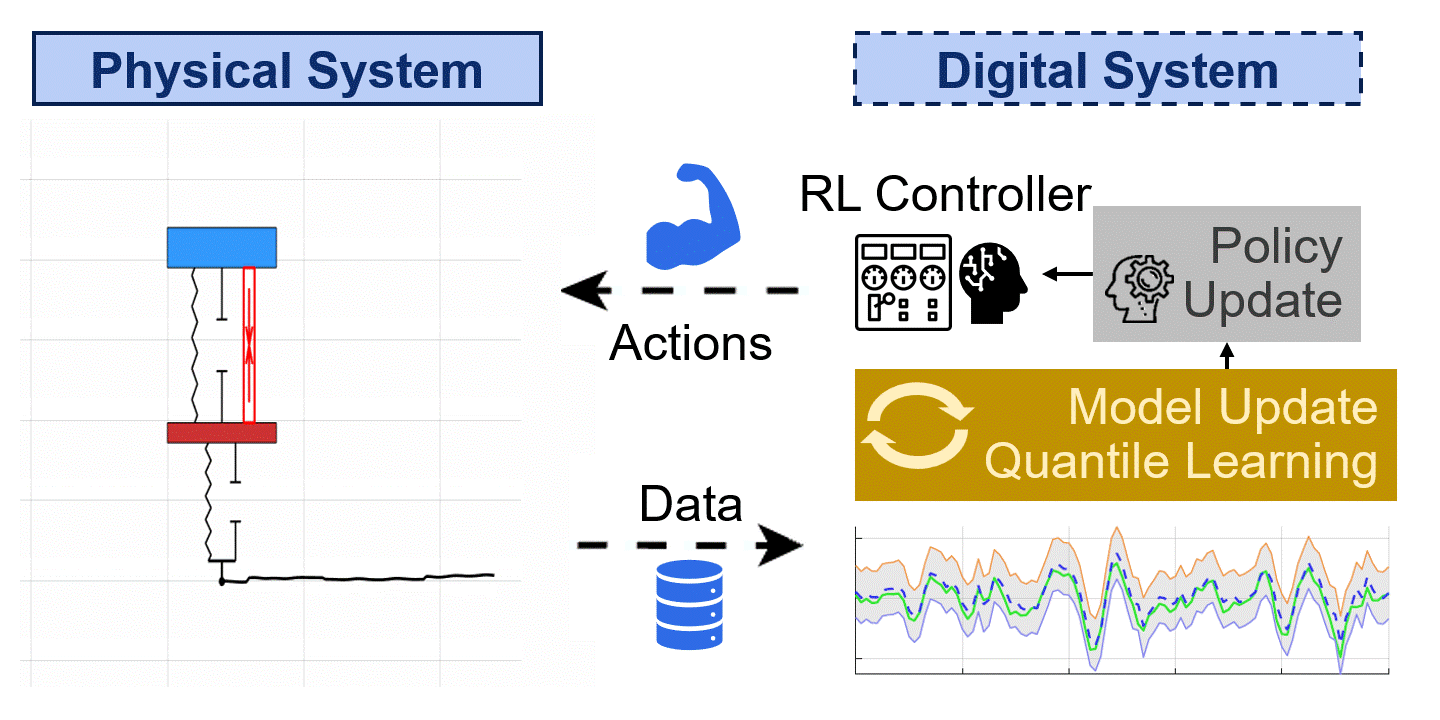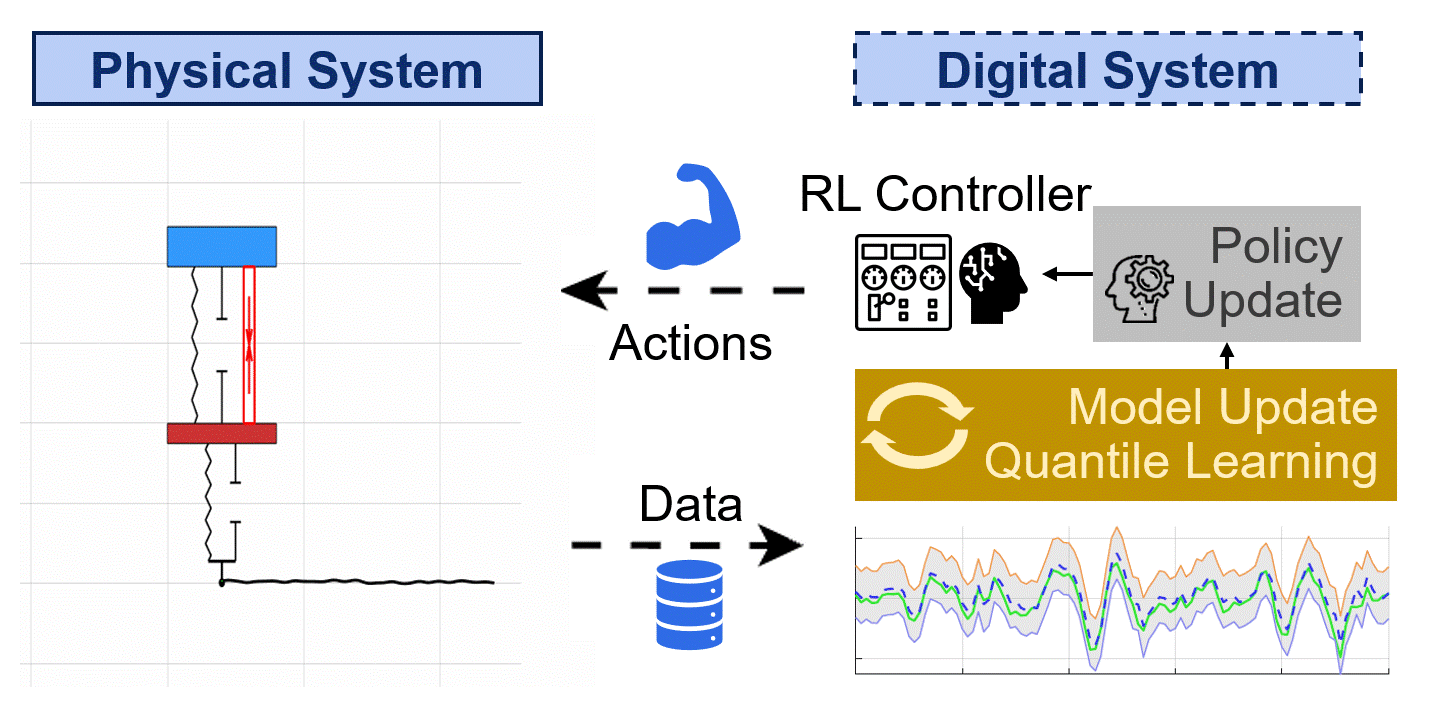
Traditional engineering design separates physical system design from controller design, solving each sequentially. This sequential approach is inherently suboptimal because a system's physical structure fundamentally shapes what controllers can achieve, and vice versa. Control Co-Design (CCD) breaks this barrier by solving both problems simultaneously, unlocking performance gains that neither approach can achieve alone.
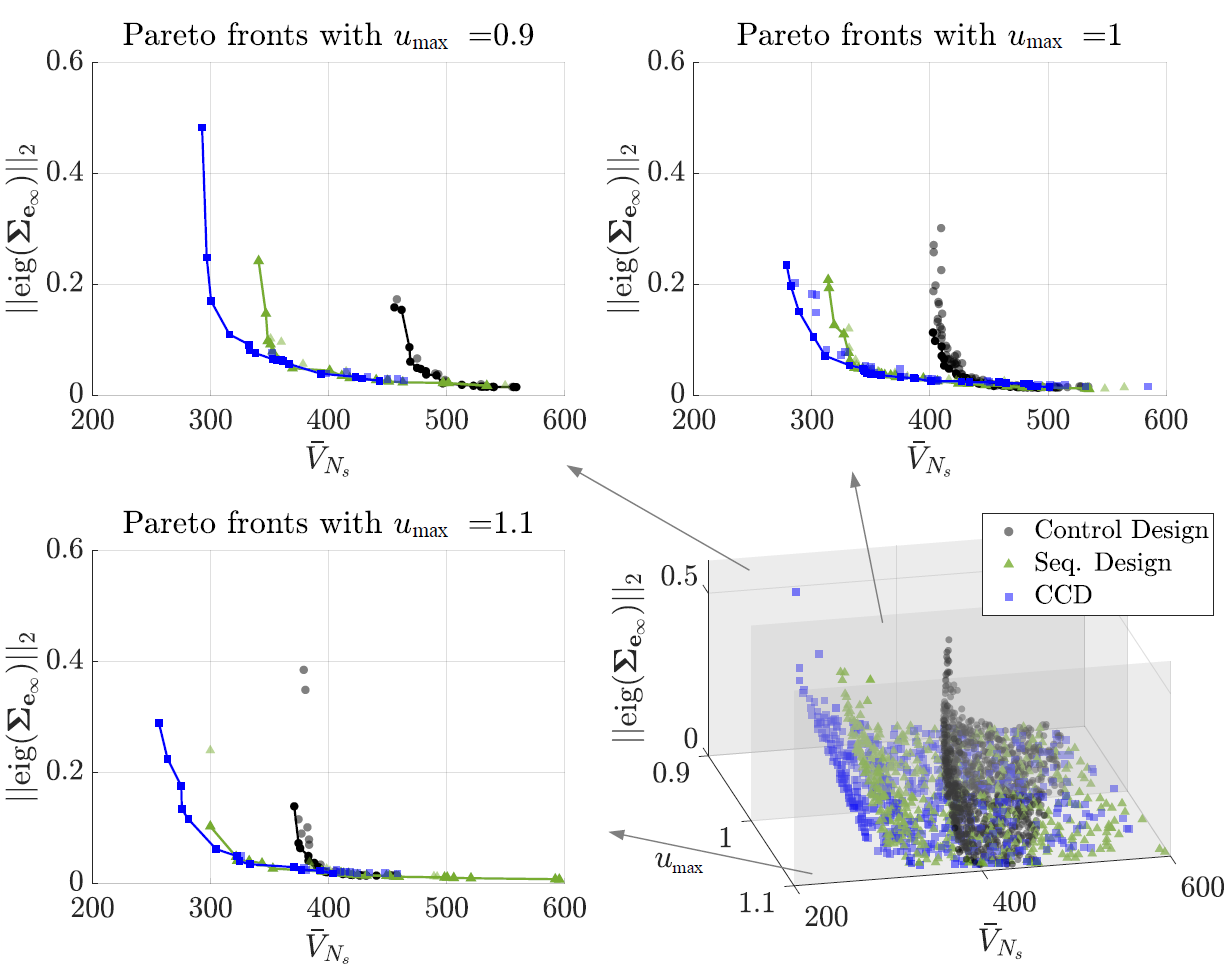
Our research develops CCD frameworks that integrate deep reinforcement learning to handle high-dimensional and nonlinear design-control spaces with constraints under isturbances. We also develop multi-objective formulations that yield a set of Pareto-optimal solutions to enable performance-robustness tradeoffs.
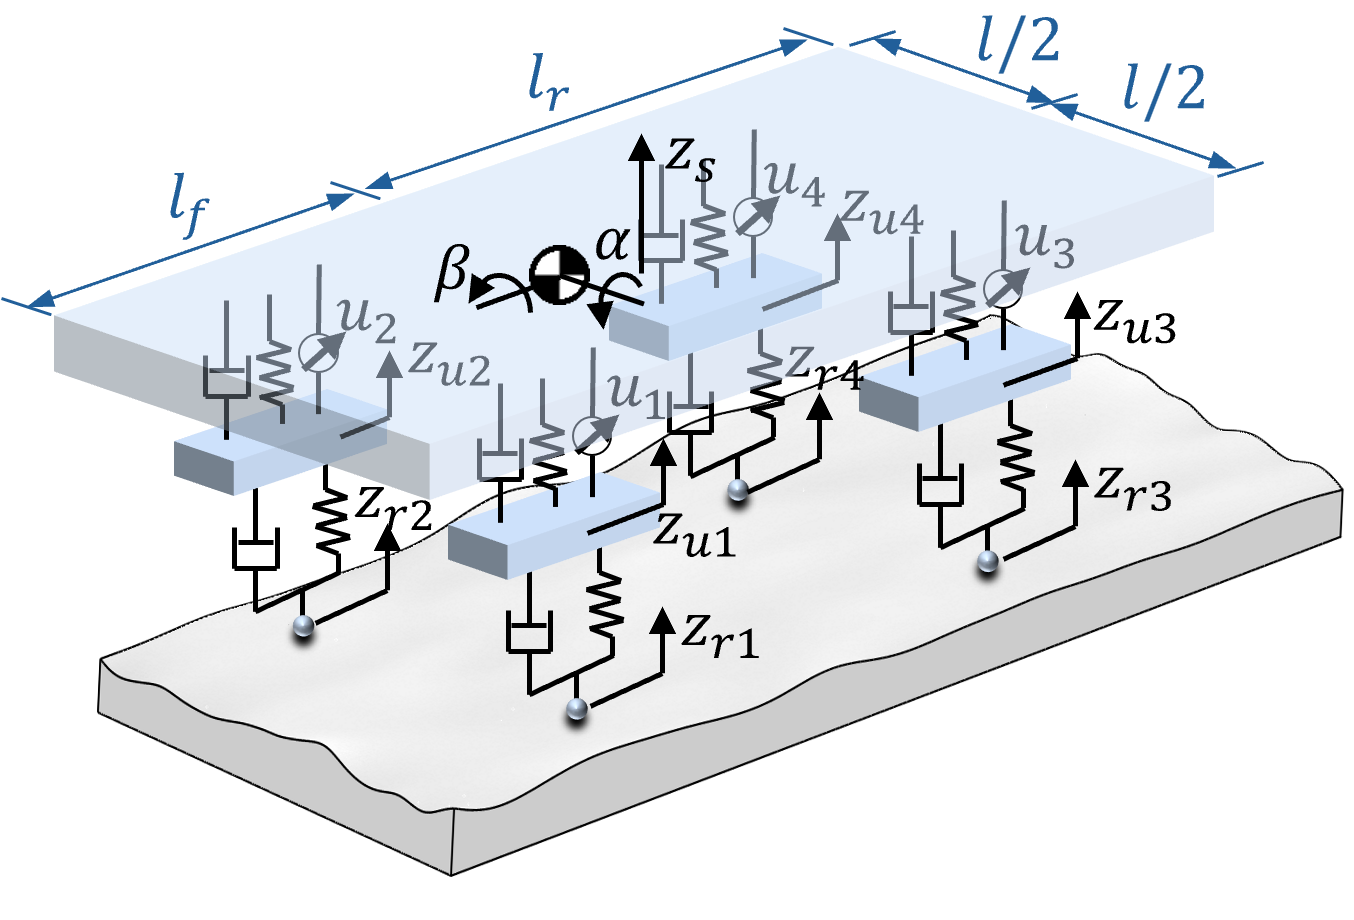
Application domains include active suspension systems, robotics, aerospace, and smart material structures. A key focus is enabling multi-generation CCD — where digital twins accumulate operational data to improve the joint design and policy in successive system iterations.
We develop both simultaneous formulations (solving design and control jointly) and nested formulations (iterating between the two), identifying when each is preferable and how to bridge them efficiently.
We leverage deep reinforcement learning to jointly optimize design parameters and control policies for complex, nonlinear systems with high-dimensional state-action spaces, without requiring explicit dynamic models.
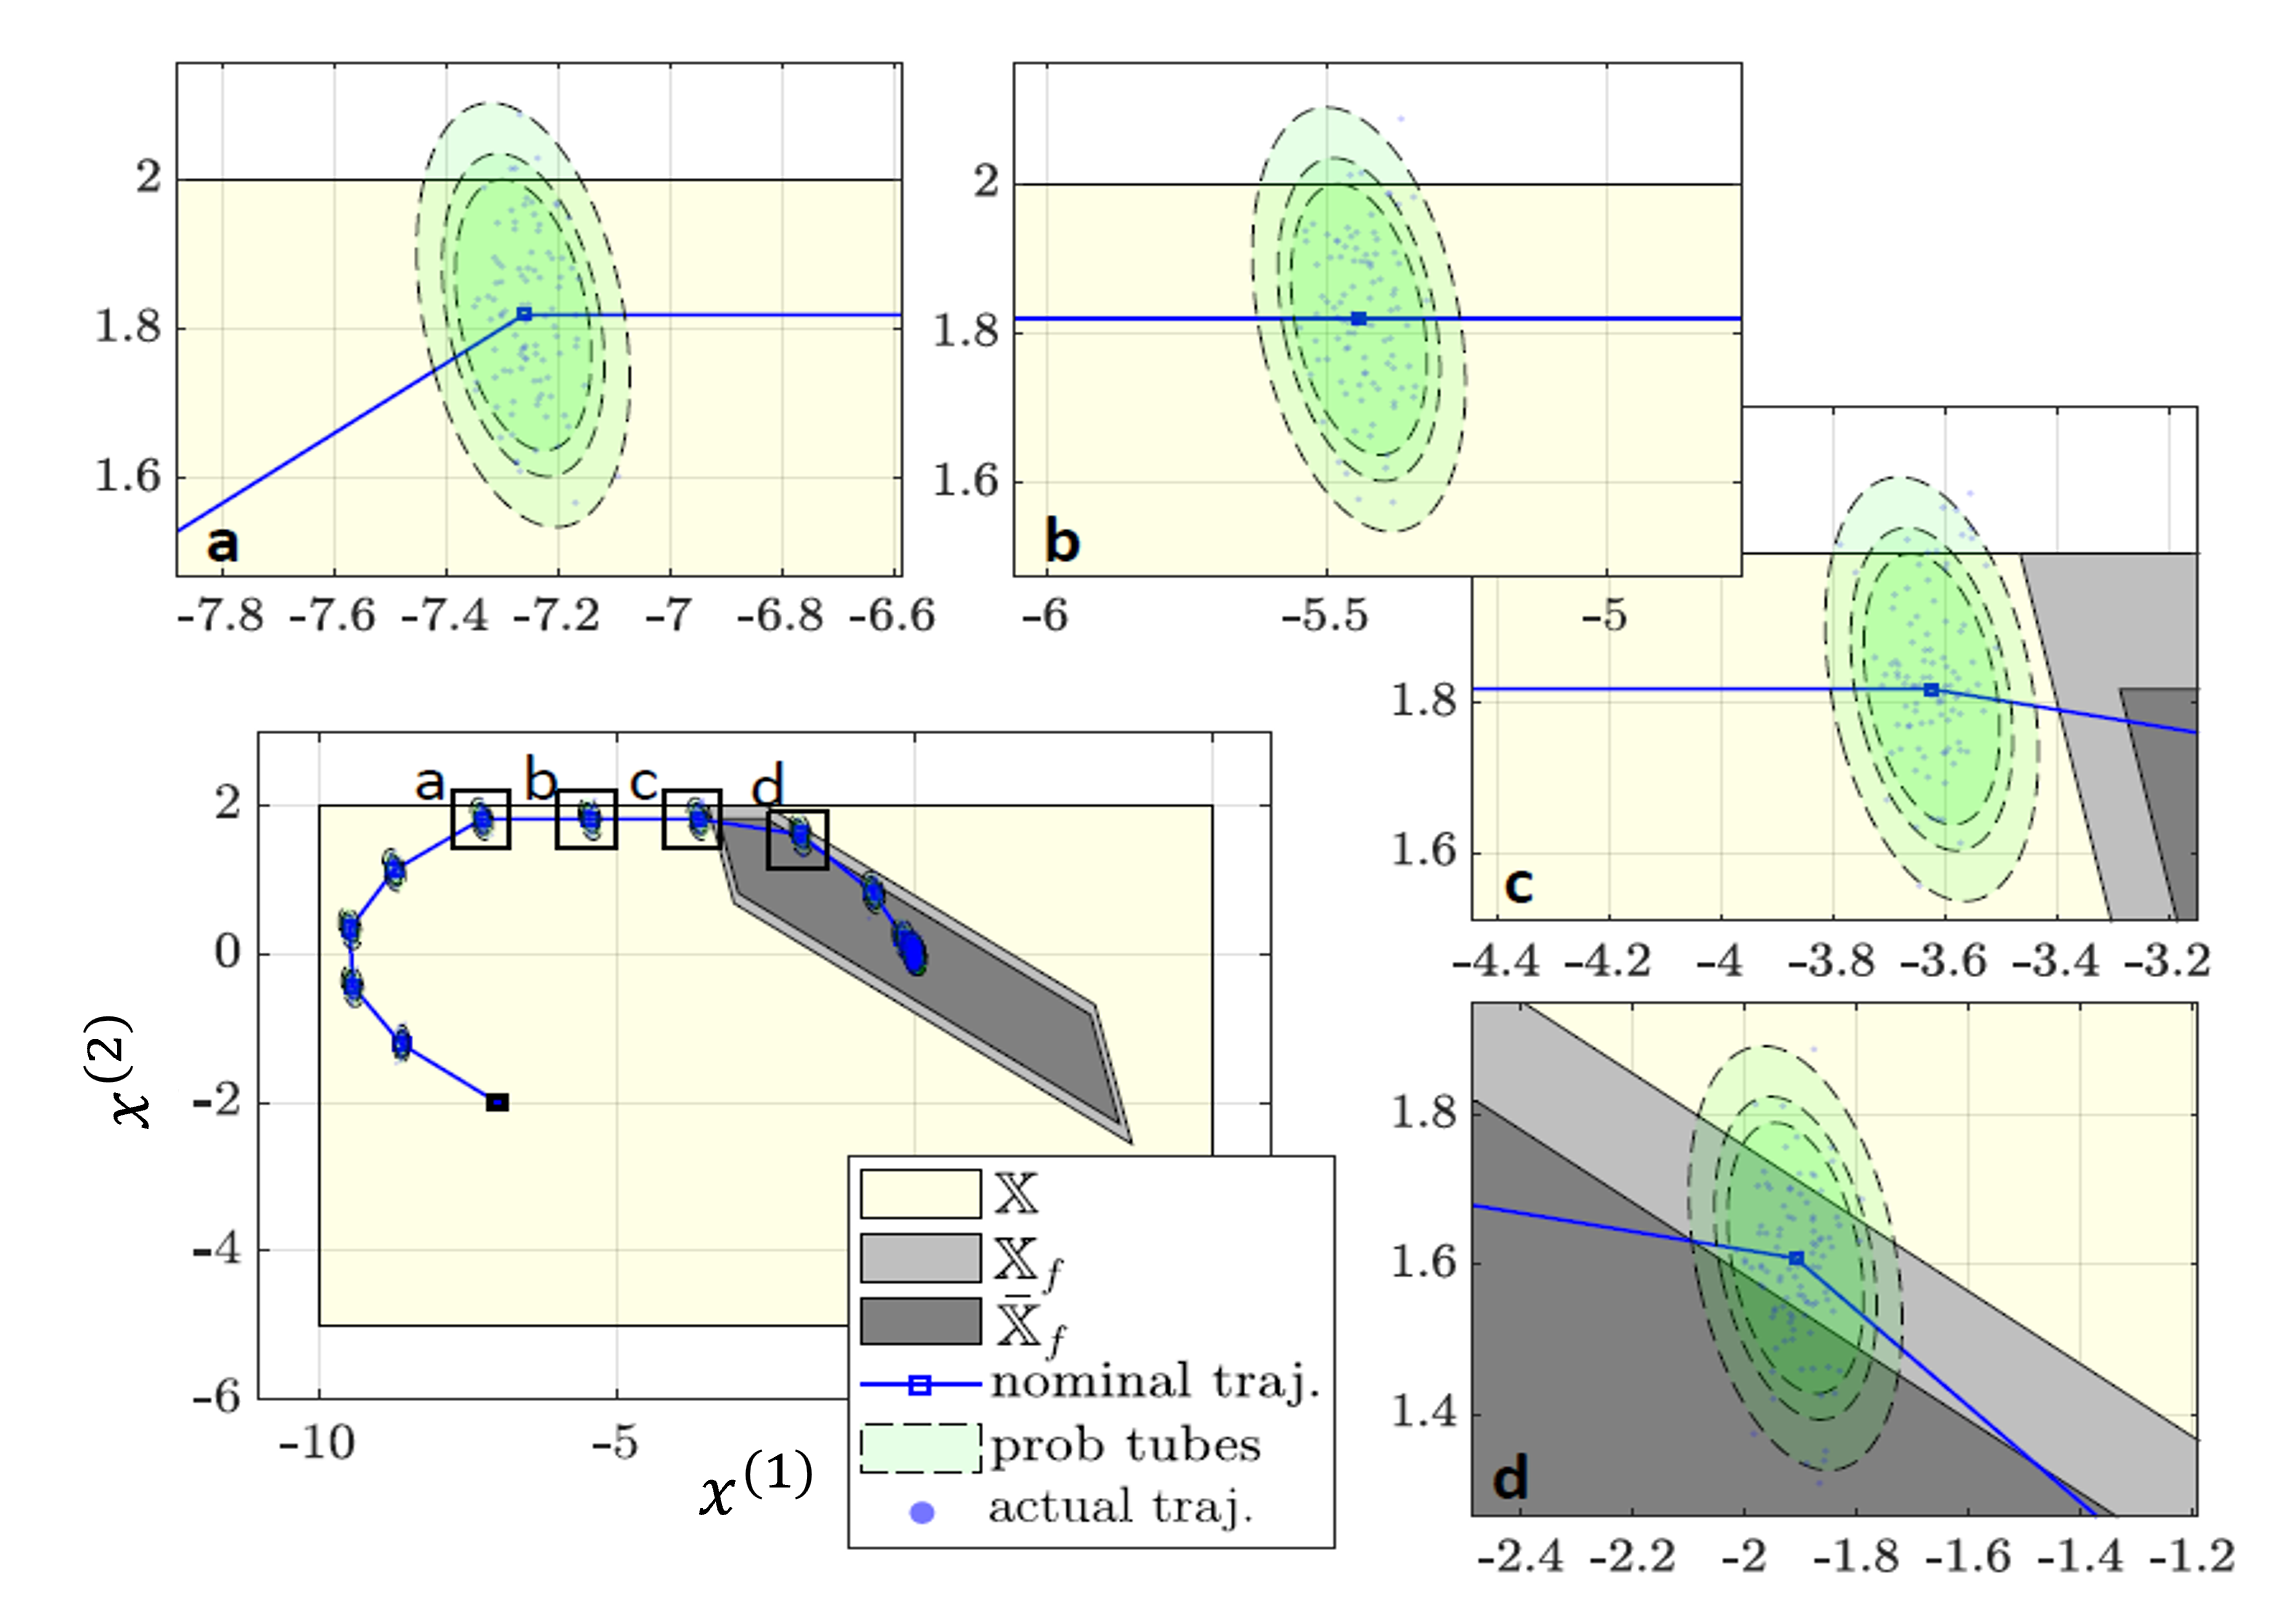
We quantify inherent uncertainty from systems and environments, including model error, sensor noise, and disturbances, and leverage it to improve system robustness. By embedding uncertainty estimates directly into the decision-making loop, we design CCD solutions that remain safe and high-performing even under real-world variability.
Selected work
Journal of Mechanical Design · April 2026
ASME Letters in Dynamic Systems and Control · July 2025